InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT > Class Template Reference
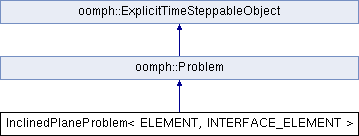
+ Inheritance diagram for InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >:
Public Member Functions

 InclinedPlaneProblem (const unsigned &nx, const unsigned &ny, const double &length)
 Generic Constructor (empty) More...
 
void solve_steady ()
 Solve the steady problem. More...
 
void timestep (const double &dt, const unsigned &n_tsteps)
 Take n_tsteps timesteps of size dt. More...
 
void actions_before_implicit_timestep ()
 
void make_traction_elements ()
 
void make_free_surface_elements ()
 
void complete_build ()
 
 ~InclinedPlaneProblem ()
 Generic desructor to clean up the memory allocated in the problem. More...
 
- Public Member Functions inherited from oomph::Problem
virtual void debug_hook_fct (const unsigned &i)
 
void set_analytic_dparameter (double *const &parameter_pt)
 
void unset_analytic_dparameter (double *const &parameter_pt)
 
bool is_dparameter_calculated_analytically (double *const &parameter_pt)
 
void set_analytic_hessian_products ()
 
void unset_analytic_hessian_products ()
 
bool are_hessian_products_calculated_analytically ()
 
void set_pinned_values_to_zero ()
 
bool distributed () const
 
virtual void actions_before_adapt ()
 
virtual void actions_after_adapt ()
 Actions that are to be performed after a mesh adaptation. More...
 
OomphCommunicator * communicator_pt ()
 access function to the oomph-lib communicator More...
 
const OomphCommunicator * communicator_pt () const
 access function to the oomph-lib communicator, const version More...
 
 Problem ()
 
 Problem (const Problem &dummy)=delete
 Broken copy constructor. More...
 
void operator= (const Problem &)=delete
 Broken assignment operator. More...
 
virtual ~Problem ()
 Virtual destructor to clean up memory. More...
 
Mesh *& mesh_pt ()
 Return a pointer to the global mesh. More...
 
Mesh *const & mesh_pt () const
 Return a pointer to the global mesh (const version) More...
 
Mesh *& mesh_pt (const unsigned &imesh)
 
Mesh *const & mesh_pt (const unsigned &imesh) const
 Return a pointer to the i-th submesh (const version) More...
 
unsigned nsub_mesh () const
 Return number of submeshes. More...
 
unsigned add_sub_mesh (Mesh *const &mesh_pt)
 
void flush_sub_meshes ()
 
void build_global_mesh ()
 
void rebuild_global_mesh ()
 
LinearSolver *& linear_solver_pt ()
 Return a pointer to the linear solver object. More...
 
LinearSolver *const & linear_solver_pt () const
 Return a pointer to the linear solver object (const version) More...
 
LinearSolver *& mass_matrix_solver_for_explicit_timestepper_pt ()
 
LinearSolver * mass_matrix_solver_for_explicit_timestepper_pt () const
 
EigenSolver *& eigen_solver_pt ()
 Return a pointer to the eigen solver object. More...
 
EigenSolver *const & eigen_solver_pt () const
 Return a pointer to the eigen solver object (const version) More...
 
Time *& time_pt ()
 Return a pointer to the global time object. More...
 
Time * time_pt () const
 Return a pointer to the global time object (const version). More...
 
double & time ()
 Return the current value of continuous time. More...
 
double time () const
 Return the current value of continuous time (const version) More...
 
TimeStepper *& time_stepper_pt ()
 
const TimeStepper * time_stepper_pt () const
 
TimeStepper *& time_stepper_pt (const unsigned &i)
 Return a pointer to the i-th timestepper. More...
 
ExplicitTimeStepper *& explicit_time_stepper_pt ()
 Return a pointer to the explicit timestepper. More...
 
unsigned long set_timestepper_for_all_data (TimeStepper *const &time_stepper_pt, const bool &preserve_existing_data=false)
 
virtual void shift_time_values ()
 Shift all values along to prepare for next timestep. More...
 
AssemblyHandler *& assembly_handler_pt ()
 Return a pointer to the assembly handler object. More...
 
AssemblyHandler *const & assembly_handler_pt () const
 Return a pointer to the assembly handler object (const version) More...
 
double & minimum_dt ()
 Access function to min timestep in adaptive timestepping. More...
 
double & maximum_dt ()
 Access function to max timestep in adaptive timestepping. More...
 
unsigned & max_newton_iterations ()
 Access function to max Newton iterations before giving up. More...
 
void problem_is_nonlinear (const bool &prob_lin)
 Access function to Problem_is_nonlinear. More...
 
double & max_residuals ()
 
bool & time_adaptive_newton_crash_on_solve_fail ()
 Access function for Time_adaptive_newton_crash_on_solve_fail. More...
 
double & newton_solver_tolerance ()
 
void add_time_stepper_pt (TimeStepper *const &time_stepper_pt)
 
void set_explicit_time_stepper_pt (ExplicitTimeStepper *const &explicit_time_stepper_pt)
 
void initialise_dt (const double &dt)
 
void initialise_dt (const Vector< double > &dt)
 
Data *& global_data_pt (const unsigned &i)
 Return a pointer to the the i-th global data object. More...
 
void add_global_data (Data *const &global_data_pt)
 
void flush_global_data ()
 
LinearAlgebraDistribution *const & dof_distribution_pt () const
 Return the pointer to the dof distribution (read-only) More...
 
unsigned long ndof () const
 Return the number of dofs. More...
 
unsigned ntime_stepper () const
 Return the number of time steppers. More...
 
unsigned nglobal_data () const
 Return the number of global data values. More...
 
unsigned self_test ()
 Self-test: Check meshes and global data. Return 0 for OK. More...
 
void enable_store_local_dof_pt_in_elements ()
 
void disable_store_local_dof_pt_in_elements ()
 
unsigned long assign_eqn_numbers (const bool &assign_local_eqn_numbers=true)
 
void describe_dofs (std::ostream &out= *(oomph_info.stream_pt())) const
 
void enable_discontinuous_formulation ()
 
void disable_discontinuous_formulation ()
 
void get_dofs (DoubleVector &dofs) const
 
void get_dofs (const unsigned &t, DoubleVector &dofs) const
 Return vector of the t'th history value of all dofs. More...
 
void set_dofs (const DoubleVector &dofs)
 Set the values of the dofs. More...
 
void set_dofs (const unsigned &t, DoubleVector &dofs)
 Set the history values of the dofs. More...
 
void set_dofs (const unsigned &t, Vector< double * > &dof_pt)
 
void add_to_dofs (const double &lambda, const DoubleVector &increment_dofs)
 Add lambda x incremenet_dofs[l] to the l-th dof. More...
 
double * global_dof_pt (const unsigned &i)
 
double & dof (const unsigned &i)
 i-th dof in the problem More...
 
double dof (const unsigned &i) const
 i-th dof in the problem (const version) More...
 
double *& dof_pt (const unsigned &i)
 Pointer to i-th dof in the problem. More...
 
double * dof_pt (const unsigned &i) const
 Pointer to i-th dof in the problem (const version) More...
 
virtual void get_inverse_mass_matrix_times_residuals (DoubleVector &Mres)
 
virtual void get_dvaluesdt (DoubleVector &f)
 
virtual void get_residuals (DoubleVector &residuals)
 Get the total residuals Vector for the problem. More...
 
virtual void get_jacobian (DoubleVector &residuals, DenseDoubleMatrix &jacobian)
 
virtual void get_jacobian (DoubleVector &residuals, CRDoubleMatrix &jacobian)
 
virtual void get_jacobian (DoubleVector &residuals, CCDoubleMatrix &jacobian)
 
virtual void get_jacobian (DoubleVector &residuals, SumOfMatrices &jacobian)
 
void get_fd_jacobian (DoubleVector &residuals, DenseMatrix< double > &jacobian)
 Get the full Jacobian by finite differencing. More...
 
void get_derivative_wrt_global_parameter (double *const &parameter_pt, DoubleVector &result)
 
void get_hessian_vector_products (DoubleVectorWithHaloEntries const &Y, Vector< DoubleVectorWithHaloEntries > const &C, Vector< DoubleVectorWithHaloEntries > &product)
 
void solve_eigenproblem (const unsigned &n_eval, Vector< std::complex< double >> &eigenvalue, Vector< DoubleVector > &eigenvector, const bool &steady=true)
 Solve the eigenproblem. More...
 
void solve_eigenproblem (const unsigned &n_eval, Vector< std::complex< double >> &eigenvalue, const bool &steady=true)
 
virtual void get_eigenproblem_matrices (CRDoubleMatrix &mass_matrix, CRDoubleMatrix &main_matrix, const double &shift=0.0)
 
void assign_eigenvector_to_dofs (DoubleVector &eigenvector)
 Assign the eigenvector passed to the function to the dofs. More...
 
void add_eigenvector_to_dofs (const double &epsilon, const DoubleVector &eigenvector)
 
void store_current_dof_values ()
 Store the current values of the degrees of freedom. More...
 
void restore_dof_values ()
 Restore the stored values of the degrees of freedom. More...
 
void enable_jacobian_reuse ()
 
void disable_jacobian_reuse ()
 Disable recycling of Jacobian in Newton iteration. More...
 
bool jacobian_reuse_is_enabled ()
 Is recycling of Jacobian in Newton iteration enabled? More...
 
bool & use_predictor_values_as_initial_guess ()
 
void newton_solve ()
 Use Newton method to solve the problem. More...
 
void enable_globally_convergent_newton_method ()
 enable globally convergent Newton method More...
 
void disable_globally_convergent_newton_method ()
 disable globally convergent Newton method More...
 
void newton_solve (unsigned const &max_adapt)
 
void steady_newton_solve (unsigned const &max_adapt=0)
 
void copy (Problem *orig_problem_pt)
 
virtual Problem * make_copy ()
 
virtual void read (std::ifstream &restart_file, bool &unsteady_restart)
 
virtual void read (std::ifstream &restart_file)
 
virtual void dump (std::ofstream &dump_file) const
 
void dump (const std::string &dump_file_name) const
 
void delete_all_external_storage ()
 
virtual void symmetrise_eigenfunction_for_adaptive_pitchfork_tracking ()
 
double * bifurcation_parameter_pt () const
 
void get_bifurcation_eigenfunction (Vector< DoubleVector > &eigenfunction)
 
void activate_fold_tracking (double *const &parameter_pt, const bool &block_solve=true)
 
void activate_bifurcation_tracking (double *const &parameter_pt, const DoubleVector &eigenvector, const bool &block_solve=true)
 
void activate_bifurcation_tracking (double *const &parameter_pt, const DoubleVector &eigenvector, const DoubleVector &normalisation, const bool &block_solve=true)
 
void activate_pitchfork_tracking (double *const &parameter_pt, const DoubleVector &symmetry_vector, const bool &block_solve=true)
 
void activate_hopf_tracking (double *const &parameter_pt, const bool &block_solve=true)
 
void activate_hopf_tracking (double *const &parameter_pt, const double &omega, const DoubleVector &null_real, const DoubleVector &null_imag, const bool &block_solve=true)
 
void deactivate_bifurcation_tracking ()
 
void reset_assembly_handler_to_default ()
 Reset the system to the standard non-augemented state. More...
 
double arc_length_step_solve (double *const &parameter_pt, const double &ds, const unsigned &max_adapt=0)
 
double arc_length_step_solve (Data *const &data_pt, const unsigned &data_index, const double &ds, const unsigned &max_adapt=0)
 
void reset_arc_length_parameters ()
 
int & sign_of_jacobian ()
 
void explicit_timestep (const double &dt, const bool &shift_values=true)
 Take an explicit timestep of size dt. More...
 
void unsteady_newton_solve (const double &dt)
 
void unsteady_newton_solve (const double &dt, const bool &shift_values)
 
void unsteady_newton_solve (const double &dt, const unsigned &max_adapt, const bool &first, const bool &shift=true)
 
double doubly_adaptive_unsteady_newton_solve (const double &dt, const double &epsilon, const unsigned &max_adapt, const bool &first, const bool &shift=true)
 
double doubly_adaptive_unsteady_newton_solve (const double &dt, const double &epsilon, const unsigned &max_adapt, const unsigned &suppress_resolve_after_spatial_adapt_flag, const bool &first, const bool &shift=true)
 
double adaptive_unsteady_newton_solve (const double &dt_desired, const double &epsilon)
 
double adaptive_unsteady_newton_solve (const double &dt_desired, const double &epsilon, const bool &shift_values)
 
void assign_initial_values_impulsive ()
 
void assign_initial_values_impulsive (const double &dt)
 
void calculate_predictions ()
 Calculate predictions. More...
 
void enable_mass_matrix_reuse ()
 
void disable_mass_matrix_reuse ()
 
bool mass_matrix_reuse_is_enabled ()
 Return whether the mass matrix is being reused. More...
 
void refine_uniformly (const Vector< unsigned > &nrefine_for_mesh)
 
void refine_uniformly (const Vector< unsigned > &nrefine_for_mesh, DocInfo &doc_info)
 
void refine_uniformly_and_prune (const Vector< unsigned > &nrefine_for_mesh)
 
void refine_uniformly_and_prune (const Vector< unsigned > &nrefine_for_mesh, DocInfo &doc_info)
 
void refine_uniformly (DocInfo &doc_info)
 
void refine_uniformly_and_prune (DocInfo &doc_info)
 
void refine_uniformly ()
 
void refine_uniformly (const unsigned &i_mesh, DocInfo &doc_info)
 Do uniform refinement for submesh i_mesh with documentation. More...
 
void refine_uniformly (const unsigned &i_mesh)
 Do uniform refinement for submesh i_mesh without documentation. More...
 
void p_refine_uniformly (const Vector< unsigned > &nrefine_for_mesh)
 
void p_refine_uniformly (const Vector< unsigned > &nrefine_for_mesh, DocInfo &doc_info)
 
void p_refine_uniformly_and_prune (const Vector< unsigned > &nrefine_for_mesh)
 
void p_refine_uniformly_and_prune (const Vector< unsigned > &nrefine_for_mesh, DocInfo &doc_info)
 
void p_refine_uniformly (DocInfo &doc_info)
 
void p_refine_uniformly_and_prune (DocInfo &doc_info)
 
void p_refine_uniformly ()
 
void p_refine_uniformly (const unsigned &i_mesh, DocInfo &doc_info)
 Do uniform p-refinement for submesh i_mesh with documentation. More...
 
void p_refine_uniformly (const unsigned &i_mesh)
 Do uniform p-refinement for submesh i_mesh without documentation. More...
 
void refine_selected_elements (const Vector< unsigned > &elements_to_be_refined)
 
void refine_selected_elements (const Vector< RefineableElement * > &elements_to_be_refined_pt)
 
void refine_selected_elements (const unsigned &i_mesh, const Vector< unsigned > &elements_to_be_refined)
 
void refine_selected_elements (const unsigned &i_mesh, const Vector< RefineableElement * > &elements_to_be_refined_pt)
 
void refine_selected_elements (const Vector< Vector< unsigned >> &elements_to_be_refined)
 
void refine_selected_elements (const Vector< Vector< RefineableElement * >> &elements_to_be_refined_pt)
 
void p_refine_selected_elements (const Vector< unsigned > &elements_to_be_refined)
 
void p_refine_selected_elements (const Vector< PRefineableElement * > &elements_to_be_refined_pt)
 
void p_refine_selected_elements (const unsigned &i_mesh, const Vector< unsigned > &elements_to_be_refined)
 
void p_refine_selected_elements (const unsigned &i_mesh, const Vector< PRefineableElement * > &elements_to_be_refined_pt)
 
void p_refine_selected_elements (const Vector< Vector< unsigned >> &elements_to_be_refined)
 
void p_refine_selected_elements (const Vector< Vector< PRefineableElement * >> &elements_to_be_refined_pt)
 
unsigned unrefine_uniformly ()
 
unsigned unrefine_uniformly (const unsigned &i_mesh)
 
void p_unrefine_uniformly (DocInfo &doc_info)
 
void p_unrefine_uniformly (const unsigned &i_mesh, DocInfo &doc_info)
 Do uniform p-unrefinement for submesh i_mesh without documentation. More...
 
void adapt (unsigned &n_refined, unsigned &n_unrefined)
 
void adapt ()
 
void p_adapt (unsigned &n_refined, unsigned &n_unrefined)
 
void p_adapt ()
 
void adapt_based_on_error_estimates (unsigned &n_refined, unsigned &n_unrefined, Vector< Vector< double >> &elemental_error)
 
void adapt_based_on_error_estimates (Vector< Vector< double >> &elemental_error)
 
void get_all_error_estimates (Vector< Vector< double >> &elemental_error)
 
void doc_errors (DocInfo &doc_info)
 Get max and min error for all elements in submeshes. More...
 
void doc_errors ()
 Get max and min error for all elements in submeshes. More...
 
void enable_info_in_newton_solve ()
 
void disable_info_in_newton_solve ()
 Disable the output of information when in the newton solver. More...
 
- Public Member Functions inherited from oomph::ExplicitTimeSteppableObject
 ExplicitTimeSteppableObject ()
 Empty constructor. More...
 
 ExplicitTimeSteppableObject (const ExplicitTimeSteppableObject &)=delete
 Broken copy constructor. More...
 
void operator= (const ExplicitTimeSteppableObject &)=delete
 Broken assignment operator. More...
 
virtual ~ExplicitTimeSteppableObject ()
 Empty destructor. More...
 
virtual void actions_before_explicit_stage ()
 
virtual void actions_after_explicit_stage ()
 

Protected Attributes

Mesh * Bulk_mesh_pt
 Bulk fluid mesh. More...
 
Mesh * Traction_mesh_pt
 Mesh for the traction elements that are added at inlet and outlet. More...
 
Mesh * Surface_mesh_pt
 Mesh for the free surface elements. More...
 
Mesh * Point_mesh_pt
 Mesh for the point elements at each end of the free surface. More...
 
std::string Output_prefix
 Prefix for output files. More...
 
- Protected Attributes inherited from oomph::Problem
Vector< Problem * > Copy_of_problem_pt
 
std::map< double *, bool > Calculate_dparameter_analytic
 
bool Calculate_hessian_products_analytic
 
LinearAlgebraDistribution * Dof_distribution_pt
 
Vector< double * > Dof_pt
 Vector of pointers to dofs. More...
 
DoubleVectorWithHaloEntries Element_count_per_dof
 
double Relaxation_factor
 
double Newton_solver_tolerance
 
unsigned Max_newton_iterations
 Maximum number of Newton iterations. More...
 
unsigned Nnewton_iter_taken
 
Vector< double > Max_res
 Maximum residuals at start and after each newton iteration. More...
 
double Max_residuals
 
bool Time_adaptive_newton_crash_on_solve_fail
 
bool Jacobian_reuse_is_enabled
 Is re-use of Jacobian in Newton iteration enabled? Default: false. More...
 
bool Jacobian_has_been_computed
 
bool Problem_is_nonlinear
 
bool Pause_at_end_of_sparse_assembly
 
bool Doc_time_in_distribute
 
unsigned Sparse_assembly_method
 
unsigned Sparse_assemble_with_arrays_initial_allocation
 
unsigned Sparse_assemble_with_arrays_allocation_increment
 
Vector< Vector< unsigned > > Sparse_assemble_with_arrays_previous_allocation
 
double Numerical_zero_for_sparse_assembly
 
double FD_step_used_in_get_hessian_vector_products
 
bool Mass_matrix_reuse_is_enabled
 
bool Mass_matrix_has_been_computed
 
bool Discontinuous_element_formulation
 
double Minimum_dt
 Minimum desired dt: if dt falls below this value, exit. More...
 
double Maximum_dt
 Maximum desired dt. More...
 
double DTSF_max_increase
 
double DTSF_min_decrease
 
double Minimum_dt_but_still_proceed
 
bool Scale_arc_length
 Boolean to control whether arc-length should be scaled. More...
 
double Desired_proportion_of_arc_length
 Proportion of the arc-length to taken by the parameter. More...
 
double Theta_squared
 
int Sign_of_jacobian
 Storage for the sign of the global Jacobian. More...
 
double Continuation_direction
 
double Parameter_derivative
 Storage for the derivative of the global parameter wrt arc-length. More...
 
double Parameter_current
 Storage for the present value of the global parameter. More...
 
bool Use_continuation_timestepper
 Boolean to control original or new storage of dof stuff. More...
 
unsigned Dof_derivative_offset
 
unsigned Dof_current_offset
 
Vector< double > Dof_derivative
 Storage for the derivative of the problem variables wrt arc-length. More...
 
Vector< double > Dof_current
 Storage for the present values of the variables. More...
 
double Ds_current
 Storage for the current step value. More...
 
unsigned Desired_newton_iterations_ds
 
double Minimum_ds
 Minimum desired value of arc-length. More...
 
bool Bifurcation_detection
 Boolean to control bifurcation detection via determinant of Jacobian. More...
 
bool Bisect_to_find_bifurcation
 Boolean to control wheter bisection is used to located bifurcation. More...
 
bool First_jacobian_sign_change
 Boolean to indicate whether a sign change has occured in the Jacobian. More...
 
bool Arc_length_step_taken
 Boolean to indicate whether an arc-length step has been taken. More...
 
bool Use_finite_differences_for_continuation_derivatives
 
OomphCommunicator * Communicator_pt
 The communicator for this problem. More...
 
bool Always_take_one_newton_step
 
double Timestep_reduction_factor_after_nonconvergence
 
bool Keep_temporal_error_below_tolerance
 

Additional Inherited Members

- Public Types inherited from oomph::Problem
typedef void(* SpatialErrorEstimatorFctPt) (Mesh *&mesh_pt, Vector< double > &elemental_error)
 Function pointer for spatial error estimator. More...
 
typedef void(* SpatialErrorEstimatorWithDocFctPt) (Mesh *&mesh_pt, Vector< double > &elemental_error, DocInfo &doc_info)
 Function pointer for spatial error estimator with doc. More...
 
- Public Attributes inherited from oomph::Problem
bool Shut_up_in_newton_solve
 
- Static Public Attributes inherited from oomph::Problem
static bool Suppress_warning_about_actions_before_read_unstructured_meshes
 
- Protected Types inherited from oomph::Problem
enum  Assembly_method {
  Perform_assembly_using_vectors_of_pairs , Perform_assembly_using_two_vectors , Perform_assembly_using_maps , Perform_assembly_using_lists ,
  Perform_assembly_using_two_arrays
}
 Enumerated flags to determine which sparse assembly method is used. More...
 
- Protected Member Functions inherited from oomph::Problem
unsigned setup_element_count_per_dof ()
 
virtual void sparse_assemble_row_or_column_compressed (Vector< int * > &column_or_row_index, Vector< int * > &row_or_column_start, Vector< double * > &value, Vector< unsigned > &nnz, Vector< double * > &residual, bool compressed_row_flag)
 
virtual void actions_before_newton_solve ()
 
virtual void actions_after_newton_solve ()
 
virtual void actions_before_newton_convergence_check ()
 
virtual void actions_before_newton_step ()
 
virtual void actions_after_newton_step ()
 
virtual void actions_after_implicit_timestep ()
 
virtual void actions_after_implicit_timestep_and_error_estimation ()
 
virtual void actions_before_explicit_timestep ()
 Actions that should be performed before each explicit time step. More...
 
virtual void actions_after_explicit_timestep ()
 Actions that should be performed after each explicit time step. More...
 
virtual void actions_before_read_unstructured_meshes ()
 
virtual void actions_after_read_unstructured_meshes ()
 
virtual void actions_after_change_in_global_parameter (double *const &parameter_pt)
 
virtual void actions_after_change_in_bifurcation_parameter ()
 
virtual void actions_after_parameter_increase (double *const &parameter_pt)
 
double & dof_derivative (const unsigned &i)
 
double & dof_current (const unsigned &i)
 
virtual void set_initial_condition ()
 
virtual double global_temporal_error_norm ()
 
unsigned newton_solve_continuation (double *const &parameter_pt)
 
unsigned newton_solve_continuation (double *const &parameter_pt, DoubleVector &z)
 
void calculate_continuation_derivatives (double *const &parameter_pt)
 
void calculate_continuation_derivatives (const DoubleVector &z)
 
void calculate_continuation_derivatives_fd (double *const &parameter_pt)
 
bool does_pointer_correspond_to_problem_data (double *const &parameter_pt)
 
void set_consistent_pinned_values_for_continuation ()
 
- Static Protected Attributes inherited from oomph::Problem
static ContinuationStorageScheme Continuation_time_stepper
 Storage for the single static continuation timestorage object. More...
 

Detailed Description

template<class ELEMENT, class INTERFACE_ELEMENT>
class InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >

Generic problem class that will form the base class for both spine and elastic mesh-updates of the problem. Templated by the bulk element and interface element types

Constructor & Destructor Documentation

◆ InclinedPlaneProblem()

template<class ELEMENT , class INTERFACE_ELEMENT >
InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::InclinedPlaneProblem ( const unsigned &  nx,
const unsigned &  ny,
const double &  length 
)
inline

Generic Constructor (empty)

162  :
163  Output_prefix("Unset") { }
std::string Output_prefix
Prefix for output files.
Definition: inclined_plane.cc:156

◆ ~InclinedPlaneProblem()

template<class ELEMENT , class INTERFACE_ELEMENT >
InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::~InclinedPlaneProblem ( )
inline

Generic desructor to clean up the memory allocated in the problem.

386  {
387  //Clear node storage before the mesh can be deleted,
388  //to avoid double deletion
390  //Then delete the mesh
391  delete this->Point_mesh_pt;
392  //Clear node storage and then delete mesh
394  delete this->Surface_mesh_pt;
395  //Clear node storage and then delete mesh
397  delete this->Traction_mesh_pt;
398  //Delete the bulk mesh (no need to clear node storage)
399  delete this->Bulk_mesh_pt;
400  //Delete the time stepper
401  delete this->time_stepper_pt();
402  }
Mesh * Bulk_mesh_pt
Bulk fluid mesh.
Definition: inclined_plane.cc:144
Mesh * Traction_mesh_pt
Mesh for the traction elements that are added at inlet and outlet.
Definition: inclined_plane.cc:147
Mesh * Surface_mesh_pt
Mesh for the free surface elements.
Definition: inclined_plane.cc:150
Mesh * Point_mesh_pt
Mesh for the point elements at each end of the free surface.
Definition: inclined_plane.cc:153
void flush_node_storage()
Definition: mesh.h:430
TimeStepper *& time_stepper_pt()
Definition: problem.h:1524

References oomph::Mesh::flush_node_storage().

Member Function Documentation

◆ actions_before_implicit_timestep()

template<class ELEMENT , class INTERFACE_ELEMENT >
void InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::actions_before_implicit_timestep ( )
inlinevirtual

Actions before the timestep (update the time-dependent boundary conditions)

Reimplemented from oomph::Problem.

174  {
175  //Read out the current time
176  double time = this->time_pt()->time();
177  //Now add a temporary sinusoidal suction and blowing to the base
178  //Amplitude of the perturbation
179  double epsilon = 0.01;
180  //Loop over the nodes on the base
181  unsigned n_node = this->Bulk_mesh_pt->nboundary_node(0);
182  for(unsigned n=0;n<n_node;n++)
183  {
184  Node* nod_pt = this->Bulk_mesh_pt->boundary_node_pt(0,n);
185  double arg = Global_Physical_Variables::K*nod_pt->x(0);
186  double value = sin(arg)*epsilon*time*exp(-time);
187  nod_pt->set_value(1,value);
188  }
189  } //end_of_actions_before_implicit_timestep
AnnoyingScalar sin(const AnnoyingScalar &x)
Definition: AnnoyingScalar.h:137
const unsigned n
Definition: CG3DPackingUnitTest.cpp:11
void set_value(const unsigned &i, const double &value_)
Definition: nodes.h:271
unsigned long nboundary_node(const unsigned &ibound) const
Return number of nodes on a particular boundary.
Definition: mesh.h:833
Node *& boundary_node_pt(const unsigned &b, const unsigned &n)
Return pointer to node n on boundary b.
Definition: mesh.h:493
Definition: nodes.h:906
double & x(const unsigned &i)
Return the i-th nodal coordinate.
Definition: nodes.h:1060
Time *& time_pt()
Return a pointer to the global time object.
Definition: problem.h:1504
double & time()
Return the current value of continuous time.
Definition: problem.cc:11531
double & time()
Return the current value of the continuous time.
Definition: timesteppers.h:123
EIGEN_STRONG_INLINE EIGEN_DEVICE_FUNC bfloat16 exp(const bfloat16 &a)
Definition: BFloat16.h:615
squared absolute value
Definition: GlobalFunctions.h:87
double K
The ratio of adsorption-desorption times.
Definition: rayleigh_instability_soluble_surfactant.cc:100
double epsilon
Definition: osc_ring_sarah_asymptotics.h:43

References oomph::Mesh::boundary_node_pt(), oomph::SarahBL::epsilon, Eigen::bfloat16_impl::exp(), Global_Physical_Variables::K, n, oomph::Mesh::nboundary_node(), oomph::Data::set_value(), sin(), Eigen::value, and oomph::Node::x().

◆ complete_build()

template<class ELEMENT , class INTERFACE_ELEMENT >
void InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::complete_build ( )
inline

Complete the build of the problem setting all standard parameters and boundary conditions

301  {
302  using namespace Global_Physical_Variables;
303 
304  //Complete the build of the fluid elements by passing physical parameters
305  //Find the number of bulk elements
306  unsigned n_element = Bulk_mesh_pt->nelement();
307  //Loop over all the fluid elements
308  for(unsigned e=0;e<n_element;e++)
309  {
310  //Cast to a fluid element
311  ELEMENT *temp_pt = dynamic_cast<ELEMENT*>(Bulk_mesh_pt->element_pt(e));
312 
313  //Set the Reynolds number
314  temp_pt->re_pt() = &Re;
315  //The Strouhal number is 1, so ReSt = Re
316  temp_pt->re_st_pt() = &Re;
317  //Set the Reynolds number / Froude number
318  temp_pt->re_invfr_pt() = &ReInvFr;
319  //Set the direction of gravity
320  temp_pt->g_pt() = &G;
321  }
322 
323  //------------Set the boundary conditions for this problem----------
324 
325  {
326  //Determine whether we are solving an elastic problem or not
327  bool elastic = false;
328  if(dynamic_cast<SolidNode*>(Bulk_mesh_pt->node_pt(0))) {elastic=true;}
329 
330  //Loop over the bottom of the mesh (the wall of the channel)
331  unsigned n_node = Bulk_mesh_pt->nboundary_node(0);
332  for(unsigned j=0;j<n_node;j++)
333  {
334  //Pin the u- and v- velocities
337 
338  //If we are formulating the elastic problem pin both positions
339  //of nodes
340  if(elastic)
341  {
342  static_cast<SolidNode*>(Bulk_mesh_pt->boundary_node_pt(0,j))
343  ->pin_position(0);
344  static_cast<SolidNode*>(Bulk_mesh_pt->boundary_node_pt(0,j))
345  ->pin_position(1);
346  }
347  }
348 
349  //Loop over the inlet and set the Dirichlet condition
350  //of no vertical velocity
351  n_node = Bulk_mesh_pt->nboundary_node(3);
352  for(unsigned j=0;j<n_node;j++)
353  {
355 
356  //If elastic pin horizontal position of nodes
357  if(elastic)
358  {
359  static_cast<SolidNode*>(Bulk_mesh_pt->boundary_node_pt(3,j))
360  ->pin_position(0);
361  }
362  }
363 
364  //Loop over the outlet and set the Dirichlet condition
365  //of no vertical velocity
366  n_node = Bulk_mesh_pt->nboundary_node(1);
367  for(unsigned j=0;j<n_node;j++)
368  {
370 
371  //If elastic pin horizontal position
372  if(elastic)
373  {
374  static_cast<SolidNode*>(Bulk_mesh_pt->boundary_node_pt(1,j))
375  ->pin_position(0);
376  }
377  }
378  }
379 
380  //Attach the boundary conditions to the mesh
381  std::cout << assign_eqn_numbers() << " in the main problem" << std::endl;
382  } //end of complete_build
Array< double, 1, 3 > e(1./3., 0.5, 2.)
JacobiRotation< float > G
Definition: Jacobi_makeGivens.cpp:2
void pin(const unsigned &i)
Pin the i-th stored variable.
Definition: nodes.h:385
GeneralisedElement *& element_pt(const unsigned long &e)
Return pointer to element e.
Definition: mesh.h:448
Node *& node_pt(const unsigned long &n)
Return pointer to global node n.
Definition: mesh.h:436
unsigned long nelement() const
Return number of elements in the mesh.
Definition: mesh.h:590
unsigned long assign_eqn_numbers(const bool &assign_local_eqn_numbers=true)
Definition: problem.cc:1989
Definition: nodes.h:1686
double ReInvFr
Product of Rynolds number and inverse of Froude number.
Definition: axisym_navier_stokes/counter_rotating_disks/counter_rotating_disks.cc:67
double Re
Reynolds number.
Definition: axisym_navier_stokes/counter_rotating_disks/counter_rotating_disks.cc:61
Global variables.
Definition: TwenteMeshGluing.cpp:60
std::ptrdiff_t j
Definition: tut_arithmetic_redux_minmax.cpp:2

References oomph::Mesh::boundary_node_pt(), e(), oomph::Mesh::element_pt(), G, j, oomph::Mesh::nboundary_node(), oomph::Mesh::nelement(), oomph::Mesh::node_pt(), oomph::Data::pin(), GlobalPhysicalVariables::Re, and GlobalPhysicalVariables::ReInvFr.

◆ make_free_surface_elements()

template<class ELEMENT , class INTERFACE_ELEMENT >
void InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::make_free_surface_elements ( )
inline
240  {
241  //Create the (empty) meshes
242  Surface_mesh_pt = new Mesh;
243  Point_mesh_pt = new Mesh;
244 
245  //The free surface is on the boundary 2
246  unsigned b = 2;
247  unsigned n_boundary_element = Bulk_mesh_pt->nboundary_element(b);
248  //Loop over the elements and create the appropriate interface elements
249  for(unsigned e=0;e<n_boundary_element;e++)
250  {
251  INTERFACE_ELEMENT *surface_element_pt =
252  new INTERFACE_ELEMENT
255  //Add elements to the mesh
256  Surface_mesh_pt->add_element_pt(surface_element_pt);
257  //Assign the capillary number to the free surface
258  surface_element_pt->ca_pt() =
260 
261  //Make a point element from left-hand side of the
262  //first surface element (note that this relies on knowledge of
263  //the element order within the mesh)
264  if(e==0)
265  {
266  FluidInterfaceBoundingElement* point_element_pt =
267  surface_element_pt->make_bounding_element(-1);
268  //Add element to the point mesh
269  Point_mesh_pt->add_element_pt(point_element_pt);
270  //Set the capillary number
271  point_element_pt->ca_pt() = &Global_Physical_Variables::Ca;
272  //Set the wall normal
273  point_element_pt->wall_unit_normal_fct_pt() =
275  //Set the contact angle (using the strong version of the constraint)
276  point_element_pt->set_contact_angle(
278  }
279 
280  //Make another point element from the right-hand side of the
281  //last surface element (note that this relies on knowledge of
282  //the element order within the mesh)
283  if(e==n_boundary_element-1)
284  {
285  FluidInterfaceBoundingElement* point_element_pt =
286  surface_element_pt->make_bounding_element(1);
287  //Add element to the mesh
288  Point_mesh_pt->add_element_pt(point_element_pt);
289  //Set the capillary number
290  point_element_pt->ca_pt() = &Global_Physical_Variables::Ca;
291  // Set the function that specifies the wall normal
292  point_element_pt->wall_unit_normal_fct_pt() =
294  }
295  }
296  } //end of make_free_surface_elements
Scalar * b
Definition: benchVecAdd.cpp:17
Definition: interface_elements.h:54
WallUnitNormalFctPt & wall_unit_normal_fct_pt()
Access function: Pointer to wall unit normal function.
Definition: interface_elements.h:141
double *& ca_pt()
Access function to the pointer specifying the capillary number.
Definition: interface_elements.h:172
void set_contact_angle(double *const &angle_pt, const bool &strong=true)
Definition: interface_elements.cc:47
Definition: mesh.h:67
int face_index_at_boundary(const unsigned &b, const unsigned &e) const
Definition: mesh.h:896
unsigned nboundary_element(const unsigned &b) const
Return number of finite elements that are adjacent to boundary b.
Definition: mesh.h:878
FiniteElement * boundary_element_pt(const unsigned &b, const unsigned &e) const
Return pointer to e-th finite element on boundary b.
Definition: mesh.h:840
void add_element_pt(GeneralisedElement *const &element_pt)
Add a (pointer to) an element to the mesh.
Definition: mesh.h:617
double Inlet_Angle
The contact angle that is imposed at the inlet (pi)
Definition: inclined_plane.cc:102
void wall_unit_normal_outlet_fct(const Vector< double > &x, Vector< double > &normal)
Function that specified the wall unit normal at the outlet.
Definition: inclined_plane.cc:91
double Ca
Capillary number.
Definition: fibre.cc:61
void wall_unit_normal_inlet_fct(const Vector< double > &x, Vector< double > &normal)
Function that specifies the wall unit normal at the inlet.
Definition: inclined_plane.cc:84

References oomph::Mesh::add_element_pt(), b, oomph::Mesh::boundary_element_pt(), Global_Physical_Variables::Ca, oomph::FluidInterfaceBoundingElement::ca_pt(), e(), oomph::Mesh::face_index_at_boundary(), Global_Physical_Variables::Inlet_Angle, oomph::Mesh::nboundary_element(), oomph::FluidInterfaceBoundingElement::set_contact_angle(), oomph::FluidInterfaceBoundingElement::wall_unit_normal_fct_pt(), Global_Physical_Variables::wall_unit_normal_inlet_fct(), and Global_Physical_Variables::wall_unit_normal_outlet_fct().

◆ make_traction_elements()

template<class ELEMENT , class INTERFACE_ELEMENT >
void InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::make_traction_elements ( )
inline

Function to add the traction boundary elements to boundaries 3(inlet) and 1(outlet) of the mesh

194  {
195  //Create a new (empty mesh)
196  Traction_mesh_pt = new Mesh;
197  //Inlet boundary conditions (boundary 3)
198  {
199  unsigned b = 3;
200  //Find the number of elements adjacent to mesh boundary
201  unsigned n_boundary_element = Bulk_mesh_pt->nboundary_element(b);
202  //Loop over these elements and create the traction elements
203  for(unsigned e=0;e<n_boundary_element;e++)
204  {
205  NavierStokesTractionElement<ELEMENT> *surface_element_pt =
209  //Add the elements to the mesh
210  Traction_mesh_pt->add_element_pt(surface_element_pt);
211  //Set the traction function
212  surface_element_pt->traction_fct_pt() =
214  }
215  }
216 
217  //Outlet boundary conditions (boundary 1)
218  {
219  unsigned b=1;
220  //Find the number of elements adjacent to mesh boundary
221  unsigned n_boundary_element = Bulk_mesh_pt->nboundary_element(b);
222  //Loop over these elements and create the traction elements
223  for(unsigned e=0;e<n_boundary_element;e++)
224  {
225  NavierStokesTractionElement<ELEMENT> *surface_element_pt =
229  //Add the elements to the mesh
230  Traction_mesh_pt->add_element_pt(surface_element_pt);
231  //Set the traction function
232  surface_element_pt->traction_fct_pt() =
234  }
235  }
236  } //end of make_traction_elements
Definition: fluid_traction_elements.h:55
void(*&)(const double &t, const Vector< double > &x, const Vector< double > &n, Vector< double > &result) traction_fct_pt()
Definition: fluid_traction_elements.h:186
void hydrostatic_pressure_outlet(const double &time, const Vector< double > &x, const Vector< double > &n, Vector< double > &traction)
Function that prescribes the hydrostatic pressure field at the outlet.
Definition: inclined_plane.cc:106
void hydrostatic_pressure_inlet(const double &time, const Vector< double > &x, const Vector< double > &n, Vector< double > &traction)
Function that prescribes hydrostatic pressure field at the inlet.
Definition: inclined_plane.cc:115

References oomph::Mesh::add_element_pt(), b, oomph::Mesh::boundary_element_pt(), e(), oomph::Mesh::face_index_at_boundary(), Global_Physical_Variables::hydrostatic_pressure_inlet(), Global_Physical_Variables::hydrostatic_pressure_outlet(), oomph::Mesh::nboundary_element(), and oomph::NavierStokesTractionElement< ELEMENT >::traction_fct_pt.

◆ solve_steady()

template<class ELEMENT , class INTERFACE_ELEMENT >
void InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::solve_steady

Solve the steady problem.

412 {
413  //Load the namespace
414  using namespace Global_Physical_Variables;
415 
416  //Initially set all nodes to the Nusselt flat-film solution
417  {
418  unsigned n_node = Bulk_mesh_pt->nnode();
419  for(unsigned n=0;n<n_node;n++)
420  {
421  double y = Bulk_mesh_pt->node_pt(n)->x(1);
422  //Top row
423  Bulk_mesh_pt->node_pt(n)->set_value(0,0.5*ReInvFr*sin(Alpha)*(2.0*y - y*y));
424  }
425  }
426 
427  //Do one steady solve
429 
430  //Output the full flow field
432  filename.append("_output.dat");
433  ofstream file(filename.c_str());
434  Bulk_mesh_pt->output(file,5);
435  file.close();
436 } //end of solve_steady
unsigned long nnode() const
Return number of nodes in the mesh.
Definition: mesh.h:596
void output(std::ostream &outfile)
Output for all elements.
Definition: mesh.cc:2027
void steady_newton_solve(unsigned const &max_adapt=0)
Definition: problem.cc:9292
Scalar * y
Definition: level1_cplx_impl.h:128
string filename
Definition: MergeRestartFiles.py:39
double Alpha
Parameter for steepness of step.
Definition: two_d_adv_diff_adapt.cc:53
std::string string(const unsigned &i)
Definition: oomph_definitions.cc:286

References TanhSolnForAdvectionDiffusion::Alpha, MergeRestartFiles::filename, n, GlobalPhysicalVariables::ReInvFr, sin(), oomph::Global_string_for_annotation::string(), and y.

◆ timestep()

template<class ELEMENT , class INTERFACE_ELEMENT >
void InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::timestep ( const double &  dt,
const unsigned &  n_tsteps 
)

Take n_tsteps timesteps of size dt.

Perform n_tsteps timesteps of size dt.

445 {
446  //Need to use the Global variables here
447  using namespace Global_Physical_Variables;
448 
449  //Open an output file
451  filename.append("_time_trace.dat");
452  ofstream trace(filename.c_str());
453  //Counter that will be used to output the full flowfield
454  //at certain timesteps
455  int counter=0;
456 
457  //Initial output of the time and the value of the vertical position at the
458  //left and right-hand end of the free surface
459  trace << time_pt()->time() << " "
460  << Bulk_mesh_pt->boundary_node_pt(2,0)->value(1)
461  << " "
462  << Bulk_mesh_pt->
463  boundary_node_pt(2, Bulk_mesh_pt->nboundary_node(2)-1)->x(1)
464  << " "
465  << std::endl;
466 
467  //Loop over the desired number of timesteps
468  for(unsigned t=1;t<=n_tsteps;t++)
469  {
470  //Increase the counter
471  counter++;
472  cout << std::endl;
473  cout << "--------------TIMESTEP " << t<< " ------------------" << std::endl;
474 
475  //Take a timestep of size dt
477 
478  //Uncomment to get full solution output
479  if(counter==2) //Change this number to get output every n steps
480  {
481  std::ofstream file;
482  std::ostringstream filename;
483  filename << Output_prefix << "_step" << Re << "_" << t << ".dat";
484  file.open(filename.str().c_str());
485  Bulk_mesh_pt->output(file,5);
486  file.close();
487 
488  counter=0;
489  }
490 
491  //Always output the interface
492  {
493  std::ofstream file;
494  std::ostringstream filename;
495  filename << Output_prefix << "_interface_" << Re << "_" << t << ".dat";
496  file.open(filename.str().c_str());
497  Surface_mesh_pt->output(file,5);
498  file.close();
499  }
500 
501  //Output the time and value of the vertical position of the free surface
502  //at the left- and right-hand ends
503  trace << time_pt()->time() << " "
504  << Bulk_mesh_pt->boundary_node_pt(2,0)->x(1) << " "
505  <<
506  Bulk_mesh_pt->
507  boundary_node_pt(2,Bulk_mesh_pt->nboundary_node(2)-1)->x(1) << " "
508  << std::endl;
509  }
510 } //end of timestep
double value(const unsigned &i) const
Definition: nodes.cc:2408
void unsteady_newton_solve(const double &dt)
Definition: problem.cc:10953
t
Definition: plotPSD.py:36

References MergeRestartFiles::filename, GlobalPhysicalVariables::Re, oomph::Global_string_for_annotation::string(), and plotPSD::t.

Member Data Documentation

◆ Bulk_mesh_pt

template<class ELEMENT , class INTERFACE_ELEMENT >
Mesh* InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::Bulk_mesh_pt
protected

Bulk fluid mesh.

◆ Output_prefix

template<class ELEMENT , class INTERFACE_ELEMENT >
std::string InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::Output_prefix
protected

Prefix for output files.

◆ Point_mesh_pt

template<class ELEMENT , class INTERFACE_ELEMENT >
Mesh* InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::Point_mesh_pt
protected

Mesh for the point elements at each end of the free surface.

◆ Surface_mesh_pt

template<class ELEMENT , class INTERFACE_ELEMENT >
Mesh* InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::Surface_mesh_pt
protected

Mesh for the free surface elements.

◆ Traction_mesh_pt

template<class ELEMENT , class INTERFACE_ELEMENT >
Mesh* InclinedPlaneProblem< ELEMENT, INTERFACE_ELEMENT >::Traction_mesh_pt
protected

Mesh for the traction elements that are added at inlet and outlet.


The documentation for this class was generated from the following file: