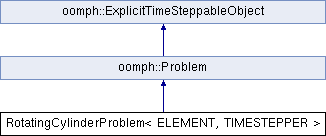
|
| | RotatingCylinderProblem (const unsigned &n_r, const unsigned &n_z, const double &l_r, const double &l_z) |
| | Constructor for refineable rotating cylinder problem. More...
|
| |
| | ~RotatingCylinderProblem () |
| | Destructor (empty) More...
|
| |
| void | set_initial_condition () |
| | Set initial conditions. More...
|
| |
| void | set_boundary_conditions () |
| | Set boundary conditions. More...
|
| |
| void | doc_solution (DocInfo &doc_info) |
| | Document the solution. More...
|
| |
| void | unsteady_run (const double &t_max, const double &dt, const string dir_name) |
| | Do unsteady run up to maximum time t_max with given timestep dt. More...
|
| |
| RefineableRectangularQuadMesh< ELEMENT > * | mesh_pt () |
| | Access function for the specific mesh. More...
|
| |
| virtual void | debug_hook_fct (const unsigned &i) |
| |
| void | set_analytic_dparameter (double *const ¶meter_pt) |
| |
| void | unset_analytic_dparameter (double *const ¶meter_pt) |
| |
| bool | is_dparameter_calculated_analytically (double *const ¶meter_pt) |
| |
| void | set_analytic_hessian_products () |
| |
| void | unset_analytic_hessian_products () |
| |
| bool | are_hessian_products_calculated_analytically () |
| |
| void | set_pinned_values_to_zero () |
| |
| bool | distributed () const |
| |
| virtual void | actions_before_adapt () |
| |
| OomphCommunicator * | communicator_pt () |
| | access function to the oomph-lib communicator More...
|
| |
| const OomphCommunicator * | communicator_pt () const |
| | access function to the oomph-lib communicator, const version More...
|
| |
| | Problem () |
| |
| | Problem (const Problem &dummy)=delete |
| | Broken copy constructor. More...
|
| |
| void | operator= (const Problem &)=delete |
| | Broken assignment operator. More...
|
| |
| virtual | ~Problem () |
| | Virtual destructor to clean up memory. More...
|
| |
| Mesh *& | mesh_pt () |
| | Return a pointer to the global mesh. More...
|
| |
| Mesh *const & | mesh_pt () const |
| | Return a pointer to the global mesh (const version) More...
|
| |
| Mesh *& | mesh_pt (const unsigned &imesh) |
| |
| Mesh *const & | mesh_pt (const unsigned &imesh) const |
| | Return a pointer to the i-th submesh (const version) More...
|
| |
| unsigned | nsub_mesh () const |
| | Return number of submeshes. More...
|
| |
| unsigned | add_sub_mesh (Mesh *const &mesh_pt) |
| |
| void | flush_sub_meshes () |
| |
| void | build_global_mesh () |
| |
| void | rebuild_global_mesh () |
| |
| LinearSolver *& | linear_solver_pt () |
| | Return a pointer to the linear solver object. More...
|
| |
| LinearSolver *const & | linear_solver_pt () const |
| | Return a pointer to the linear solver object (const version) More...
|
| |
| LinearSolver *& | mass_matrix_solver_for_explicit_timestepper_pt () |
| |
| LinearSolver * | mass_matrix_solver_for_explicit_timestepper_pt () const |
| |
| EigenSolver *& | eigen_solver_pt () |
| | Return a pointer to the eigen solver object. More...
|
| |
| EigenSolver *const & | eigen_solver_pt () const |
| | Return a pointer to the eigen solver object (const version) More...
|
| |
| Time *& | time_pt () |
| | Return a pointer to the global time object. More...
|
| |
| Time * | time_pt () const |
| | Return a pointer to the global time object (const version). More...
|
| |
| double & | time () |
| | Return the current value of continuous time. More...
|
| |
| double | time () const |
| | Return the current value of continuous time (const version) More...
|
| |
| TimeStepper *& | time_stepper_pt () |
| |
| const TimeStepper * | time_stepper_pt () const |
| |
| TimeStepper *& | time_stepper_pt (const unsigned &i) |
| | Return a pointer to the i-th timestepper. More...
|
| |
| ExplicitTimeStepper *& | explicit_time_stepper_pt () |
| | Return a pointer to the explicit timestepper. More...
|
| |
| unsigned long | set_timestepper_for_all_data (TimeStepper *const &time_stepper_pt, const bool &preserve_existing_data=false) |
| |
| virtual void | shift_time_values () |
| | Shift all values along to prepare for next timestep. More...
|
| |
| AssemblyHandler *& | assembly_handler_pt () |
| | Return a pointer to the assembly handler object. More...
|
| |
| AssemblyHandler *const & | assembly_handler_pt () const |
| | Return a pointer to the assembly handler object (const version) More...
|
| |
| double & | minimum_dt () |
| | Access function to min timestep in adaptive timestepping. More...
|
| |
| double & | maximum_dt () |
| | Access function to max timestep in adaptive timestepping. More...
|
| |
| unsigned & | max_newton_iterations () |
| | Access function to max Newton iterations before giving up. More...
|
| |
| void | problem_is_nonlinear (const bool &prob_lin) |
| | Access function to Problem_is_nonlinear. More...
|
| |
| double & | max_residuals () |
| |
| bool & | time_adaptive_newton_crash_on_solve_fail () |
| | Access function for Time_adaptive_newton_crash_on_solve_fail. More...
|
| |
| double & | newton_solver_tolerance () |
| |
| void | add_time_stepper_pt (TimeStepper *const &time_stepper_pt) |
| |
| void | set_explicit_time_stepper_pt (ExplicitTimeStepper *const &explicit_time_stepper_pt) |
| |
| void | initialise_dt (const double &dt) |
| |
| void | initialise_dt (const Vector< double > &dt) |
| |
| Data *& | global_data_pt (const unsigned &i) |
| | Return a pointer to the the i-th global data object. More...
|
| |
| void | add_global_data (Data *const &global_data_pt) |
| |
| void | flush_global_data () |
| |
| LinearAlgebraDistribution *const & | dof_distribution_pt () const |
| | Return the pointer to the dof distribution (read-only) More...
|
| |
| unsigned long | ndof () const |
| | Return the number of dofs. More...
|
| |
| unsigned | ntime_stepper () const |
| | Return the number of time steppers. More...
|
| |
| unsigned | nglobal_data () const |
| | Return the number of global data values. More...
|
| |
| unsigned | self_test () |
| | Self-test: Check meshes and global data. Return 0 for OK. More...
|
| |
| void | enable_store_local_dof_pt_in_elements () |
| |
| void | disable_store_local_dof_pt_in_elements () |
| |
| unsigned long | assign_eqn_numbers (const bool &assign_local_eqn_numbers=true) |
| |
| void | describe_dofs (std::ostream &out= *(oomph_info.stream_pt())) const |
| |
| void | enable_discontinuous_formulation () |
| |
| void | disable_discontinuous_formulation () |
| |
| void | get_dofs (DoubleVector &dofs) const |
| |
| void | get_dofs (const unsigned &t, DoubleVector &dofs) const |
| | Return vector of the t'th history value of all dofs. More...
|
| |
| void | set_dofs (const DoubleVector &dofs) |
| | Set the values of the dofs. More...
|
| |
| void | set_dofs (const unsigned &t, DoubleVector &dofs) |
| | Set the history values of the dofs. More...
|
| |
| void | set_dofs (const unsigned &t, Vector< double * > &dof_pt) |
| |
| void | add_to_dofs (const double &lambda, const DoubleVector &increment_dofs) |
| | Add lambda x incremenet_dofs[l] to the l-th dof. More...
|
| |
| double * | global_dof_pt (const unsigned &i) |
| |
| double & | dof (const unsigned &i) |
| | i-th dof in the problem More...
|
| |
| double | dof (const unsigned &i) const |
| | i-th dof in the problem (const version) More...
|
| |
| double *& | dof_pt (const unsigned &i) |
| | Pointer to i-th dof in the problem. More...
|
| |
| double * | dof_pt (const unsigned &i) const |
| | Pointer to i-th dof in the problem (const version) More...
|
| |
| virtual void | get_inverse_mass_matrix_times_residuals (DoubleVector &Mres) |
| |
| virtual void | get_dvaluesdt (DoubleVector &f) |
| |
| virtual void | get_residuals (DoubleVector &residuals) |
| | Get the total residuals Vector for the problem. More...
|
| |
| virtual void | get_jacobian (DoubleVector &residuals, DenseDoubleMatrix &jacobian) |
| |
| virtual void | get_jacobian (DoubleVector &residuals, CRDoubleMatrix &jacobian) |
| |
| virtual void | get_jacobian (DoubleVector &residuals, CCDoubleMatrix &jacobian) |
| |
| virtual void | get_jacobian (DoubleVector &residuals, SumOfMatrices &jacobian) |
| |
| void | get_fd_jacobian (DoubleVector &residuals, DenseMatrix< double > &jacobian) |
| | Get the full Jacobian by finite differencing. More...
|
| |
| void | get_derivative_wrt_global_parameter (double *const ¶meter_pt, DoubleVector &result) |
| |
| void | get_hessian_vector_products (DoubleVectorWithHaloEntries const &Y, Vector< DoubleVectorWithHaloEntries > const &C, Vector< DoubleVectorWithHaloEntries > &product) |
| |
| void | solve_eigenproblem (const unsigned &n_eval, Vector< std::complex< double >> &eigenvalue, Vector< DoubleVector > &eigenvector, const bool &steady=true) |
| | Solve the eigenproblem. More...
|
| |
| void | solve_eigenproblem (const unsigned &n_eval, Vector< std::complex< double >> &eigenvalue, const bool &steady=true) |
| |
| virtual void | get_eigenproblem_matrices (CRDoubleMatrix &mass_matrix, CRDoubleMatrix &main_matrix, const double &shift=0.0) |
| |
| void | assign_eigenvector_to_dofs (DoubleVector &eigenvector) |
| | Assign the eigenvector passed to the function to the dofs. More...
|
| |
| void | add_eigenvector_to_dofs (const double &epsilon, const DoubleVector &eigenvector) |
| |
| void | store_current_dof_values () |
| | Store the current values of the degrees of freedom. More...
|
| |
| void | restore_dof_values () |
| | Restore the stored values of the degrees of freedom. More...
|
| |
| void | enable_jacobian_reuse () |
| |
| void | disable_jacobian_reuse () |
| | Disable recycling of Jacobian in Newton iteration. More...
|
| |
| bool | jacobian_reuse_is_enabled () |
| | Is recycling of Jacobian in Newton iteration enabled? More...
|
| |
| bool & | use_predictor_values_as_initial_guess () |
| |
| void | newton_solve () |
| | Use Newton method to solve the problem. More...
|
| |
| void | enable_globally_convergent_newton_method () |
| | enable globally convergent Newton method More...
|
| |
| void | disable_globally_convergent_newton_method () |
| | disable globally convergent Newton method More...
|
| |
| void | newton_solve (unsigned const &max_adapt) |
| |
| void | steady_newton_solve (unsigned const &max_adapt=0) |
| |
| void | copy (Problem *orig_problem_pt) |
| |
| virtual Problem * | make_copy () |
| |
| virtual void | read (std::ifstream &restart_file, bool &unsteady_restart) |
| |
| virtual void | read (std::ifstream &restart_file) |
| |
| virtual void | dump (std::ofstream &dump_file) const |
| |
| void | dump (const std::string &dump_file_name) const |
| |
| void | delete_all_external_storage () |
| |
| virtual void | symmetrise_eigenfunction_for_adaptive_pitchfork_tracking () |
| |
| double * | bifurcation_parameter_pt () const |
| |
| void | get_bifurcation_eigenfunction (Vector< DoubleVector > &eigenfunction) |
| |
| void | activate_fold_tracking (double *const ¶meter_pt, const bool &block_solve=true) |
| |
| void | activate_bifurcation_tracking (double *const ¶meter_pt, const DoubleVector &eigenvector, const bool &block_solve=true) |
| |
| void | activate_bifurcation_tracking (double *const ¶meter_pt, const DoubleVector &eigenvector, const DoubleVector &normalisation, const bool &block_solve=true) |
| |
| void | activate_pitchfork_tracking (double *const ¶meter_pt, const DoubleVector &symmetry_vector, const bool &block_solve=true) |
| |
| void | activate_hopf_tracking (double *const ¶meter_pt, const bool &block_solve=true) |
| |
| void | activate_hopf_tracking (double *const ¶meter_pt, const double &omega, const DoubleVector &null_real, const DoubleVector &null_imag, const bool &block_solve=true) |
| |
| void | deactivate_bifurcation_tracking () |
| |
| void | reset_assembly_handler_to_default () |
| | Reset the system to the standard non-augemented state. More...
|
| |
| double | arc_length_step_solve (double *const ¶meter_pt, const double &ds, const unsigned &max_adapt=0) |
| |
| double | arc_length_step_solve (Data *const &data_pt, const unsigned &data_index, const double &ds, const unsigned &max_adapt=0) |
| |
| void | reset_arc_length_parameters () |
| |
| int & | sign_of_jacobian () |
| |
| void | explicit_timestep (const double &dt, const bool &shift_values=true) |
| | Take an explicit timestep of size dt. More...
|
| |
| void | unsteady_newton_solve (const double &dt) |
| |
| void | unsteady_newton_solve (const double &dt, const bool &shift_values) |
| |
| void | unsteady_newton_solve (const double &dt, const unsigned &max_adapt, const bool &first, const bool &shift=true) |
| |
| double | doubly_adaptive_unsteady_newton_solve (const double &dt, const double &epsilon, const unsigned &max_adapt, const bool &first, const bool &shift=true) |
| |
| double | doubly_adaptive_unsteady_newton_solve (const double &dt, const double &epsilon, const unsigned &max_adapt, const unsigned &suppress_resolve_after_spatial_adapt_flag, const bool &first, const bool &shift=true) |
| |
| double | adaptive_unsteady_newton_solve (const double &dt_desired, const double &epsilon) |
| |
| double | adaptive_unsteady_newton_solve (const double &dt_desired, const double &epsilon, const bool &shift_values) |
| |
| void | assign_initial_values_impulsive () |
| |
| void | assign_initial_values_impulsive (const double &dt) |
| |
| void | calculate_predictions () |
| | Calculate predictions. More...
|
| |
| void | enable_mass_matrix_reuse () |
| |
| void | disable_mass_matrix_reuse () |
| |
| bool | mass_matrix_reuse_is_enabled () |
| | Return whether the mass matrix is being reused. More...
|
| |
| void | refine_uniformly (const Vector< unsigned > &nrefine_for_mesh) |
| |
| void | refine_uniformly (const Vector< unsigned > &nrefine_for_mesh, DocInfo &doc_info) |
| |
| void | refine_uniformly_and_prune (const Vector< unsigned > &nrefine_for_mesh) |
| |
| void | refine_uniformly_and_prune (const Vector< unsigned > &nrefine_for_mesh, DocInfo &doc_info) |
| |
| void | refine_uniformly (DocInfo &doc_info) |
| |
| void | refine_uniformly_and_prune (DocInfo &doc_info) |
| |
| void | refine_uniformly () |
| |
| void | refine_uniformly (const unsigned &i_mesh, DocInfo &doc_info) |
| | Do uniform refinement for submesh i_mesh with documentation. More...
|
| |
| void | refine_uniformly (const unsigned &i_mesh) |
| | Do uniform refinement for submesh i_mesh without documentation. More...
|
| |
| void | p_refine_uniformly (const Vector< unsigned > &nrefine_for_mesh) |
| |
| void | p_refine_uniformly (const Vector< unsigned > &nrefine_for_mesh, DocInfo &doc_info) |
| |
| void | p_refine_uniformly_and_prune (const Vector< unsigned > &nrefine_for_mesh) |
| |
| void | p_refine_uniformly_and_prune (const Vector< unsigned > &nrefine_for_mesh, DocInfo &doc_info) |
| |
| void | p_refine_uniformly (DocInfo &doc_info) |
| |
| void | p_refine_uniformly_and_prune (DocInfo &doc_info) |
| |
| void | p_refine_uniformly () |
| |
| void | p_refine_uniformly (const unsigned &i_mesh, DocInfo &doc_info) |
| | Do uniform p-refinement for submesh i_mesh with documentation. More...
|
| |
| void | p_refine_uniformly (const unsigned &i_mesh) |
| | Do uniform p-refinement for submesh i_mesh without documentation. More...
|
| |
| void | refine_selected_elements (const Vector< unsigned > &elements_to_be_refined) |
| |
| void | refine_selected_elements (const Vector< RefineableElement * > &elements_to_be_refined_pt) |
| |
| void | refine_selected_elements (const unsigned &i_mesh, const Vector< unsigned > &elements_to_be_refined) |
| |
| void | refine_selected_elements (const unsigned &i_mesh, const Vector< RefineableElement * > &elements_to_be_refined_pt) |
| |
| void | refine_selected_elements (const Vector< Vector< unsigned >> &elements_to_be_refined) |
| |
| void | refine_selected_elements (const Vector< Vector< RefineableElement * >> &elements_to_be_refined_pt) |
| |
| void | p_refine_selected_elements (const Vector< unsigned > &elements_to_be_refined) |
| |
| void | p_refine_selected_elements (const Vector< PRefineableElement * > &elements_to_be_refined_pt) |
| |
| void | p_refine_selected_elements (const unsigned &i_mesh, const Vector< unsigned > &elements_to_be_refined) |
| |
| void | p_refine_selected_elements (const unsigned &i_mesh, const Vector< PRefineableElement * > &elements_to_be_refined_pt) |
| |
| void | p_refine_selected_elements (const Vector< Vector< unsigned >> &elements_to_be_refined) |
| |
| void | p_refine_selected_elements (const Vector< Vector< PRefineableElement * >> &elements_to_be_refined_pt) |
| |
| unsigned | unrefine_uniformly () |
| |
| unsigned | unrefine_uniformly (const unsigned &i_mesh) |
| |
| void | p_unrefine_uniformly (DocInfo &doc_info) |
| |
| void | p_unrefine_uniformly (const unsigned &i_mesh, DocInfo &doc_info) |
| | Do uniform p-unrefinement for submesh i_mesh without documentation. More...
|
| |
| void | adapt (unsigned &n_refined, unsigned &n_unrefined) |
| |
| void | adapt () |
| |
| void | p_adapt (unsigned &n_refined, unsigned &n_unrefined) |
| |
| void | p_adapt () |
| |
| void | adapt_based_on_error_estimates (unsigned &n_refined, unsigned &n_unrefined, Vector< Vector< double >> &elemental_error) |
| |
| void | adapt_based_on_error_estimates (Vector< Vector< double >> &elemental_error) |
| |
| void | get_all_error_estimates (Vector< Vector< double >> &elemental_error) |
| |
| void | doc_errors (DocInfo &doc_info) |
| | Get max and min error for all elements in submeshes. More...
|
| |
| void | doc_errors () |
| | Get max and min error for all elements in submeshes. More...
|
| |
| void | enable_info_in_newton_solve () |
| |
| void | disable_info_in_newton_solve () |
| | Disable the output of information when in the newton solver. More...
|
| |
| | ExplicitTimeSteppableObject () |
| | Empty constructor. More...
|
| |
| | ExplicitTimeSteppableObject (const ExplicitTimeSteppableObject &)=delete |
| | Broken copy constructor. More...
|
| |
| void | operator= (const ExplicitTimeSteppableObject &)=delete |
| | Broken assignment operator. More...
|
| |
| virtual | ~ExplicitTimeSteppableObject () |
| | Empty destructor. More...
|
| |
| virtual void | actions_before_explicit_stage () |
| |
| virtual void | actions_after_explicit_stage () |
| |
|
| typedef void(* | SpatialErrorEstimatorFctPt) (Mesh *&mesh_pt, Vector< double > &elemental_error) |
| | Function pointer for spatial error estimator. More...
|
| |
| typedef void(* | SpatialErrorEstimatorWithDocFctPt) (Mesh *&mesh_pt, Vector< double > &elemental_error, DocInfo &doc_info) |
| | Function pointer for spatial error estimator with doc. More...
|
| |
| bool | Shut_up_in_newton_solve |
| |
| static bool | Suppress_warning_about_actions_before_read_unstructured_meshes |
| |
| enum | Assembly_method {
Perform_assembly_using_vectors_of_pairs
, Perform_assembly_using_two_vectors
, Perform_assembly_using_maps
, Perform_assembly_using_lists
,
Perform_assembly_using_two_arrays
} |
| | Enumerated flags to determine which sparse assembly method is used. More...
|
| |
| unsigned | setup_element_count_per_dof () |
| |
| virtual void | sparse_assemble_row_or_column_compressed (Vector< int * > &column_or_row_index, Vector< int * > &row_or_column_start, Vector< double * > &value, Vector< unsigned > &nnz, Vector< double * > &residual, bool compressed_row_flag) |
| |
| virtual void | actions_before_newton_convergence_check () |
| |
| virtual void | actions_before_newton_step () |
| |
| virtual void | actions_after_newton_step () |
| |
| virtual void | actions_before_implicit_timestep () |
| |
| virtual void | actions_after_implicit_timestep () |
| |
| virtual void | actions_after_implicit_timestep_and_error_estimation () |
| |
| virtual void | actions_before_explicit_timestep () |
| | Actions that should be performed before each explicit time step. More...
|
| |
| virtual void | actions_after_explicit_timestep () |
| | Actions that should be performed after each explicit time step. More...
|
| |
| virtual void | actions_before_read_unstructured_meshes () |
| |
| virtual void | actions_after_read_unstructured_meshes () |
| |
| virtual void | actions_after_change_in_global_parameter (double *const ¶meter_pt) |
| |
| virtual void | actions_after_change_in_bifurcation_parameter () |
| |
| virtual void | actions_after_parameter_increase (double *const ¶meter_pt) |
| |
| double & | dof_derivative (const unsigned &i) |
| |
| double & | dof_current (const unsigned &i) |
| |
| virtual double | global_temporal_error_norm () |
| |
| unsigned | newton_solve_continuation (double *const ¶meter_pt) |
| |
| unsigned | newton_solve_continuation (double *const ¶meter_pt, DoubleVector &z) |
| |
| void | calculate_continuation_derivatives (double *const ¶meter_pt) |
| |
| void | calculate_continuation_derivatives (const DoubleVector &z) |
| |
| void | calculate_continuation_derivatives_fd (double *const ¶meter_pt) |
| |
| bool | does_pointer_correspond_to_problem_data (double *const ¶meter_pt) |
| |
| void | set_consistent_pinned_values_for_continuation () |
| |
| Vector< Problem * > | Copy_of_problem_pt |
| |
| std::map< double *, bool > | Calculate_dparameter_analytic |
| |
| bool | Calculate_hessian_products_analytic |
| |
| LinearAlgebraDistribution * | Dof_distribution_pt |
| |
| Vector< double * > | Dof_pt |
| | Vector of pointers to dofs. More...
|
| |
| DoubleVectorWithHaloEntries | Element_count_per_dof |
| |
| double | Relaxation_factor |
| |
| double | Newton_solver_tolerance |
| |
| unsigned | Max_newton_iterations |
| | Maximum number of Newton iterations. More...
|
| |
| unsigned | Nnewton_iter_taken |
| |
| Vector< double > | Max_res |
| | Maximum residuals at start and after each newton iteration. More...
|
| |
| double | Max_residuals |
| |
| bool | Time_adaptive_newton_crash_on_solve_fail |
| |
| bool | Jacobian_reuse_is_enabled |
| | Is re-use of Jacobian in Newton iteration enabled? Default: false. More...
|
| |
| bool | Jacobian_has_been_computed |
| |
| bool | Problem_is_nonlinear |
| |
| bool | Pause_at_end_of_sparse_assembly |
| |
| bool | Doc_time_in_distribute |
| |
| unsigned | Sparse_assembly_method |
| |
| unsigned | Sparse_assemble_with_arrays_initial_allocation |
| |
| unsigned | Sparse_assemble_with_arrays_allocation_increment |
| |
| Vector< Vector< unsigned > > | Sparse_assemble_with_arrays_previous_allocation |
| |
| double | Numerical_zero_for_sparse_assembly |
| |
| double | FD_step_used_in_get_hessian_vector_products |
| |
| bool | Mass_matrix_reuse_is_enabled |
| |
| bool | Mass_matrix_has_been_computed |
| |
| bool | Discontinuous_element_formulation |
| |
| double | Minimum_dt |
| | Minimum desired dt: if dt falls below this value, exit. More...
|
| |
| double | Maximum_dt |
| | Maximum desired dt. More...
|
| |
| double | DTSF_max_increase |
| |
| double | DTSF_min_decrease |
| |
| double | Minimum_dt_but_still_proceed |
| |
| bool | Scale_arc_length |
| | Boolean to control whether arc-length should be scaled. More...
|
| |
| double | Desired_proportion_of_arc_length |
| | Proportion of the arc-length to taken by the parameter. More...
|
| |
| double | Theta_squared |
| |
| int | Sign_of_jacobian |
| | Storage for the sign of the global Jacobian. More...
|
| |
| double | Continuation_direction |
| |
| double | Parameter_derivative |
| | Storage for the derivative of the global parameter wrt arc-length. More...
|
| |
| double | Parameter_current |
| | Storage for the present value of the global parameter. More...
|
| |
| bool | Use_continuation_timestepper |
| | Boolean to control original or new storage of dof stuff. More...
|
| |
| unsigned | Dof_derivative_offset |
| |
| unsigned | Dof_current_offset |
| |
| Vector< double > | Dof_derivative |
| | Storage for the derivative of the problem variables wrt arc-length. More...
|
| |
| Vector< double > | Dof_current |
| | Storage for the present values of the variables. More...
|
| |
| double | Ds_current |
| | Storage for the current step value. More...
|
| |
| unsigned | Desired_newton_iterations_ds |
| |
| double | Minimum_ds |
| | Minimum desired value of arc-length. More...
|
| |
| bool | Bifurcation_detection |
| | Boolean to control bifurcation detection via determinant of Jacobian. More...
|
| |
| bool | Bisect_to_find_bifurcation |
| | Boolean to control wheter bisection is used to located bifurcation. More...
|
| |
| bool | First_jacobian_sign_change |
| | Boolean to indicate whether a sign change has occured in the Jacobian. More...
|
| |
| bool | Arc_length_step_taken |
| | Boolean to indicate whether an arc-length step has been taken. More...
|
| |
| bool | Use_finite_differences_for_continuation_derivatives |
| |
| OomphCommunicator * | Communicator_pt |
| | The communicator for this problem. More...
|
| |
| bool | Always_take_one_newton_step |
| |
| double | Timestep_reduction_factor_after_nonconvergence |
| |
| bool | Keep_temporal_error_below_tolerance |
| |
| static ContinuationStorageScheme | Continuation_time_stepper |
| | Storage for the single static continuation timestorage object. More...
|
| |
 Inheritance diagram for RotatingCylinderProblem< ELEMENT, TIMESTEPPER >:
 1.9.1